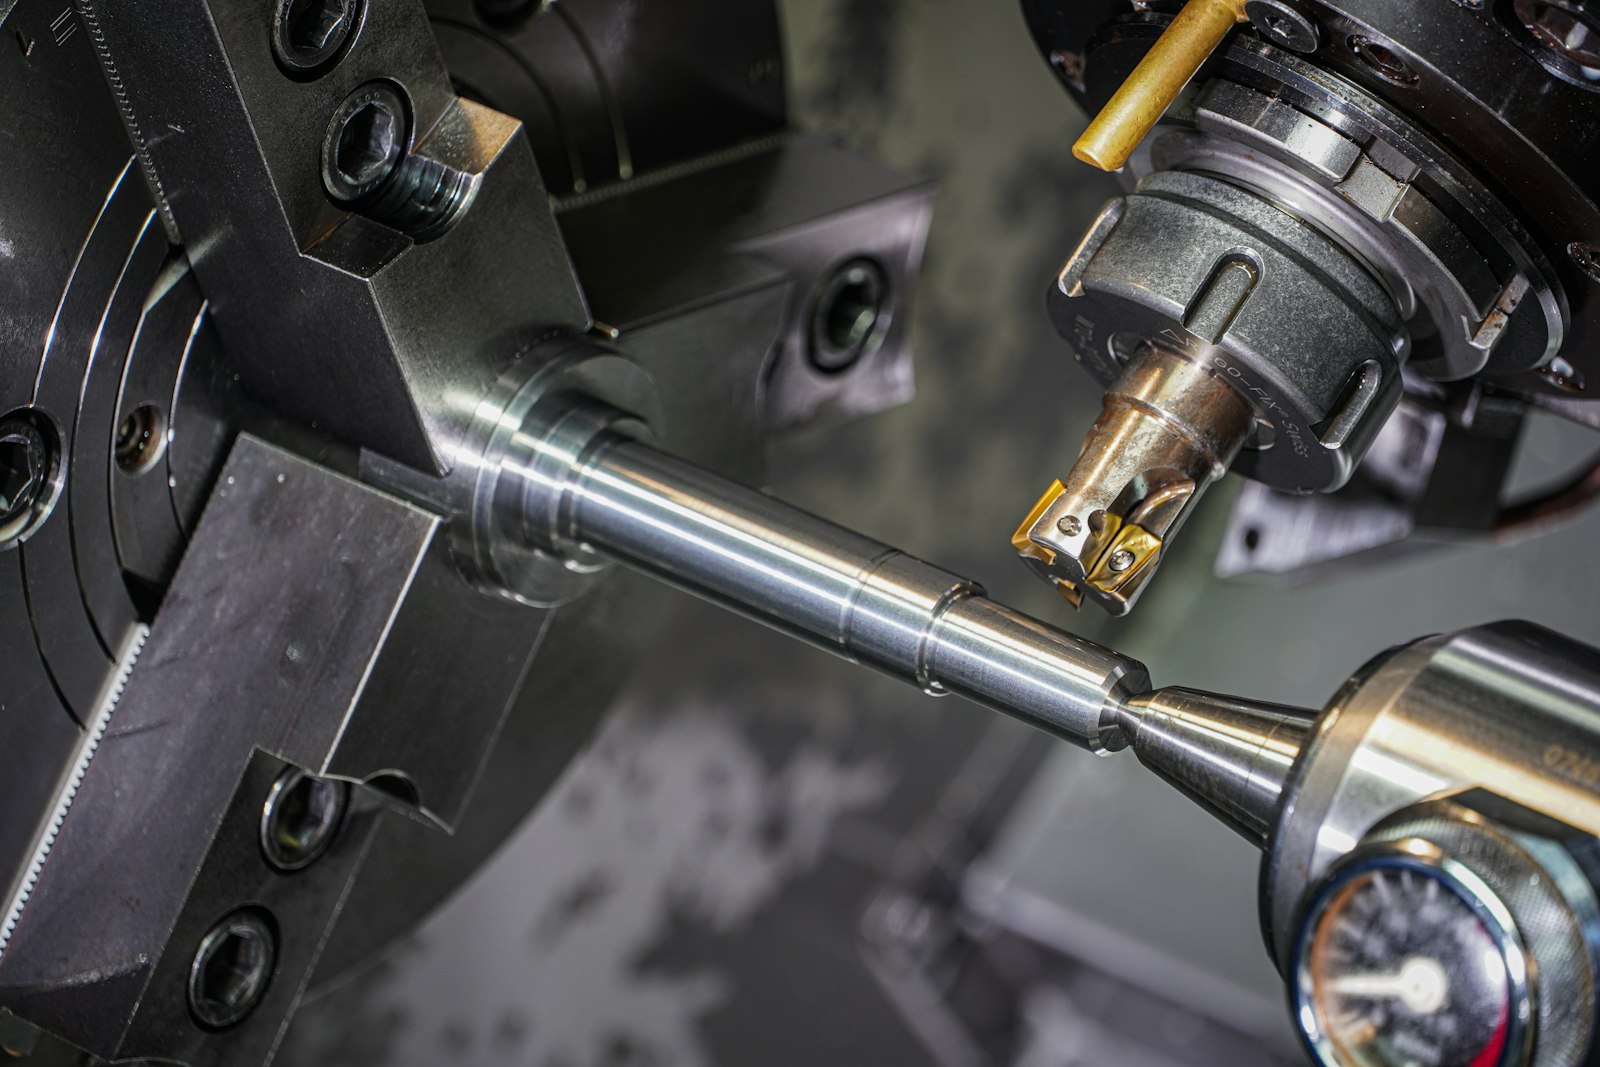
 Photo: Sven Daniel / Unsplash
"Which sensors do we actually need?" is the question we hear most often on discovery calls, usually right after "will it work on our machine?" The honest answer is that it depends on the physics of the failure you care about, not on what a vendor happens to sell. Here is how we think about it, and a simple decision guide you can apply to your own line.
What each modality is good at
Vibration (contact accelerometers)
Vibration is the gold standard for rotating machinery: bearings, gearboxes, unbalance, misalignment, looseness. A well-mounted accelerometer gives a clean, repeatable signal with well-understood diagnostic rules (ISO 10816 and friends). Its limits are practical: it needs a rigid mounting point, one sensor covers one asset, and it says little about processes that do not shake the housing.
Airborne acoustic (audible, 20 Hz to 20 kHz)
Microphones hear what an experienced operator hears: a change in the cutting sound, a squeal, a knock, a compressor labouring. One microphone can cover several machines. The price is noise: the plant is loud, other machines interfere, and the signal depends on where the microphone is. This is exactly where modern signal processing and learned representations earn their keep, and where naive approaches fail.
Ultrasonic (20 kHz to 100 kHz and beyond)
Above human hearing the world gets quieter and more specific. Compressed-air leaks, steam trap failures, electrical arcing and partial discharge, early-stage bearing lubrication problems and friction all radiate ultrasound strongly and directionally. Background noise is much lower, so detection is easier, but the sensors, sampling rates and data volumes are more demanding.
Acoustic emission (structure-borne, 100 kHz to 1 MHz)
Acoustic emission sensors coupled to the structure pick up crack growth, weld pool events and material transitions as they happen. This is what we used for in-process monitoring of joint-gap formation in laser welding. It is the most process-specific modality and the one most dependent on sensor placement and coupling.
A decision guide
- Name the failure mode, not the asset. "Bearing wear on the main spindle" points to vibration. "Porosity in the weld seam" points to acoustic emission or high-frequency airborne acoustics. "Leaks in the pneumatic line" points to ultrasound. "Something sounds off on the extruder" points to audible acoustics plus process signals.
- Ask how the phenomenon radiates. Does it shake the housing (vibration), disturb the air (acoustic), or emit high-frequency stress waves in the material (AE)? Many problems do more than one, which is the argument for multi-modal units.
- Check what you already have. Spindle load, motor current and PLC tags are free sensors. Sometimes the acoustic sensor only needs to explain what the PLC already sees.
- Estimate coverage per sensor. If you need to monitor 40 machines, a contact sensor on each is a project in itself. Two microphones per bay may be enough to catch the failures you care about.
- Test it before you buy it. A short measurement campaign with a portable multi-modal unit shows, in days, which channels carry the signature. That is the whole point of a feasibility study.
Why we default to multi-modal
The strongest results we have seen come from fusing modalities: audible acoustics for context, ultrasound for early and specific events, vibration for the rotating parts, and a camera or lidar where geometry matters. Fusion is also how you get robustness. A microphone that is fooled by a forklift is corrected by the accelerometer that felt nothing. Our sensor units with NeuroControls GmbH exist for exactly this reason: vision, audible and ultrasonic audio, vibration, lidar, temperature, humidity and gas in one synchronised platform, so the fusion happens in the data, not in a slide.
That said, we do not sell sensors first. If your failure mode is a classic bearing problem, we will tell you to keep your accelerometers and spend the money on a better evaluation protocol.
Key takeaways
- Choose the modality from the physics of the failure mode, not from the asset type.
- Vibration for rotating parts; audible acoustics for process context and coverage; ultrasound for leaks, arcing and early friction; acoustic emission for in-process material events.
- Existing PLC and current signals are free sensors; use them.
- Multi-modal fusion buys robustness against plant noise.
- A short measurement campaign answers the sensor question in days.
If any of this matches a problem on your line, the fastest way to find out what is possible is a free discovery call followed, where it makes sense, by a feasibility study of two to ten days.